Building an Actuator for a Walking Robot: A Complex Journey
The quest to create robots that mimic human movement presents unique challenges, particularly when it comes to developing compact, powerful, and efficient actuators. Walking robots, in particular, face a significant disadvantage due to the lack of fast and powerful linear actuators that can be easily integrated into their design. This is where [Food for Robots] comes in, tackling the complex task of building a joint-mounted actuator for their walking robot.
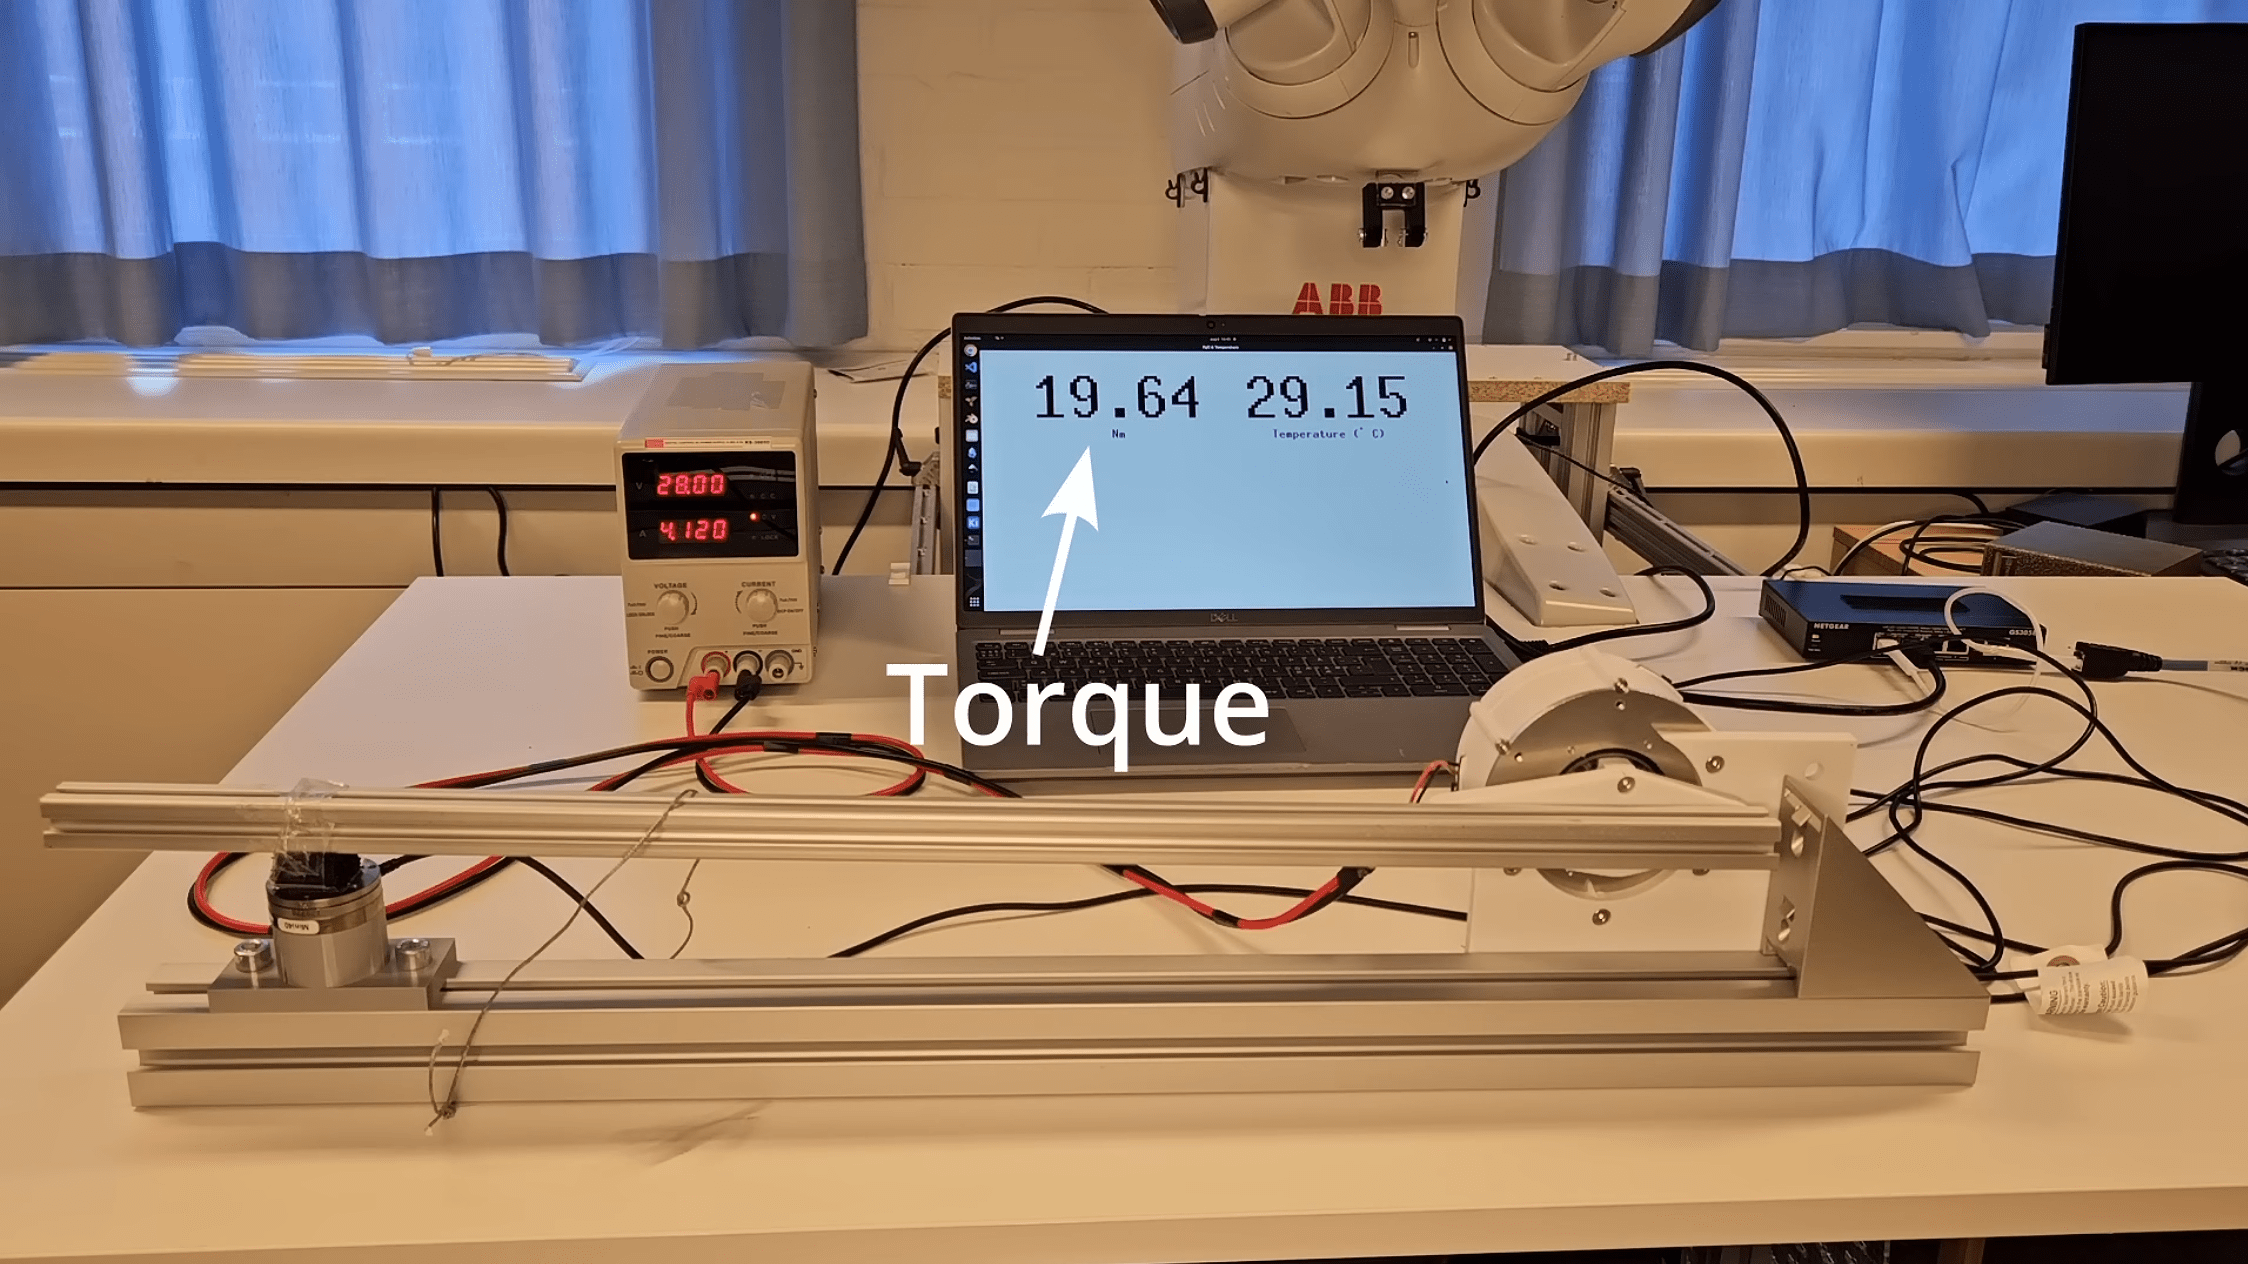
In their latest endeavor, [Food for Robots] aimed to create a lightweight and backdrivable actuator capable of generating 20 Newton-meters of torque. This is a crucial requirement for their robot's mobility and functionality. The previous iteration, largely 3D-printed, had its limitations, breaking under the strain of exceeding 10 Newton-meters of torque. To address this, [Food for Robots] decided to machine the second iteration out of aluminum, a more robust material.
One of the key innovations in this design is the use of a planetary gearbox, which sits at the center of the actuator, inside the stator. This gearbox utilizes stacked layers of gears to increase strength and efficiency within the constraints of a small CNC machine. The motor's rotor features a small magnet, which is used by the control board to read the position, ensuring precise control.
However, the journey to success was not without its hurdles. [Food for Robots] encountered a challenge when they found that increasing the number of windings did not improve power output. This was due to the reduction in wire count, which inadvertently increased resistance. To overcome this, they had to increase the current limits in the field-oriented control algorithm, allowing the actuator to reach the desired 20 Newton-meters of torque.
This project highlights the intricate nature of robotics and the need for innovative solutions to overcome technical challenges. The use of a planetary gearbox and the careful consideration of power output demonstrate the complexity of creating efficient and reliable actuators for walking robots. As [Food for Robots] continues to refine their design, we can expect to see further advancements in the field of robotic mobility and control.
In conclusion, building an actuator for a walking robot is a complex and rewarding endeavor. It requires a deep understanding of mechanical engineering, materials science, and control systems. As the field of robotics continues to evolve, we can anticipate more sophisticated and efficient solutions to the challenges of creating agile and capable walking robots.